Monday brief
Underwater robots
Robust Object Detection for Underwater Robots via Domain Generalization.
Quinn Ellis
Desk note
Brief tip
The full sticky-note brief continues below on the Monday desk.
Board
Desk Notes
Robust Object Detection for Underwater Robots via Domain Generalization.
Overview
Object detection combines the tasks of identifying what an object is and where it is located. Underwater environments, however, introduce unique difficulties for detection systems. Common challenges include occlusion, camouflage, domain shift, and reduced visibility. This study focuses on developing robust object detection methods specifically designed for underwater robotic systems.
Plain-Language Summary
The underwater world is notoriously difficult for machines to interpret visually. Imagine trying to spot a fish hiding behind others, blending into coral, or swimming through murky, tinted waters. Underwater robots face this challenge constantly, whether they are monitoring fish farms, studying marine life, or collecting seafood.
The researchers identify four key obstacles for underwater object detection. First, marine animals often cluster together, making it hard to distinguish individuals. Second, many species have evolved camouflage to match their environment. Third, water changes the appearance of objects, often casting a blue or green tint that confuses models trained on regular above-water images. Finally, movement through water stirs up sediment and generates motion blur, further reducing clarity.
Think of it as finding a friend in a well-lit shopping mall versus in a dark, crowded nightclub with fog machines. The friend is the same, but the environment makes recognition far more difficult.
This paper proposes a detection system designed to overcome these challenges, giving underwater robots more reliable “eyes” in difficult conditions.
Key Findings
The study addresses several major underwater detection problems:
Occlusion: Overlapping animals make standard systems fail. The research develops methods to improve detection in crowded underwater scenes.
Camouflage: Detecting animals that blend into their surroundings is challenging. The system uses techniques to highlight subtle differences between objects and background.
Domain shift: Underwater color casts and distortions reduce accuracy. Image enhancement and domain adaptation methods allow the system to generalize to varying water conditions.
Turbidity and motion blur: Strategies like integrating information across multiple frames increase the signal-to-noise ratio, improving visibility in murky conditions.
The paper also outlines how these improvements can be implemented on robots with limited computing resources.
Technical Approach
The researchers analyze how conventional object detection architectures fail underwater. To address occlusion, they introduce advanced non-maximum suppression methods that distinguish overlapping targets. For camouflage, the system extracts fine-grained texture and edge features that traditional convolutional networks might miss.
Domain shift is handled with a two-step approach: first, preprocessing corrects color and contrast; second, domain adaptation techniques allow the detector to generalize across diverse underwater settings. To tackle turbidity and motion blur, the system integrates temporal information from multiple frames, enhancing detection performance compared to single-frame methods.
The architecture is optimized for real-time operation on robots with constrained processing power, and image enhancement effects are evaluated across different water types and visibility levels.
Critical Analysis
While promising, the system has limitations. Test environments may not represent all underwater conditions worldwide. Tropical reefs, kelp forests, and polar waters present unique visual challenges.
The focus is mainly on detection accuracy, not energy efficiency. Robots have limited power, so a highly accurate but energy-intensive system could be impractical. The system also needs evaluation on previously unseen species, as biodiversity underwater is vast.
Standardized benchmark datasets are lacking, making comparisons with other methods difficult. Additionally, integration with higher-level robotic decision-making systems is not fully addressed—detection is only one part of a complete robotic perception-action loop.
Conclusion
Underwater object detection requires specialized solutions beyond standard computer vision. This research advances the field by addressing occlusion, camouflage, domain shift, and turbidity, providing reliable detection in challenging conditions.
Applications extend to marine industries like aquaculture, environmental monitoring, and fisheries management, improving efficiency and sustainability. The technology also supports scientific research, underwater archaeology, infrastructure inspection, and search-and-rescue operations.
Future work should aim to improve robustness under extreme conditions, reduce energy consumption, and detect previously unseen objects. With continued development, underwater robots equipped with advanced vision systems may soon become essential tools for ocean exploration and management.
More from this board
NOTE · en
World Globes and Their Advantages
In a world where digital maps, GPS systems, and satellite photographs have become part of everyday life, the traditional globe still offers something uniquely valuable.
NOTE · en
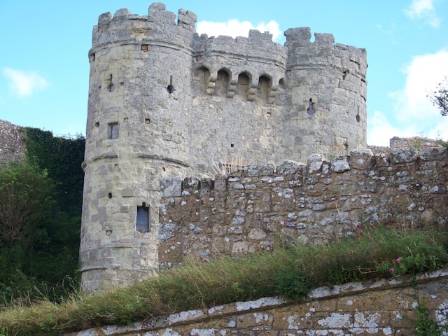
Guédelon Castle: Building a Medieval Fortress Through Experimental Archaeology
In the forested heart of Burgundy’s Puisaye region, 100 miles southeast of Paris, a thirteenth-century castle is rising—one stone, one timber, and one hand-forged nail at a time. Guédelon Castle, nestled in an abandoned quarry, is no mere replica; it is the world’s most ambitious and longest-running experimental archaeology project. Since 1998, a team of 40 artisans, builders, and researchers has labored to construct a medieval fortress using only the tools, techniques, and materials available in the 1200s. Their mission: to uncover the lost knowledge of medieval craftsmanship, fill gaps in archaeological understanding, and bring to life the realities of building in an era without power tools, concrete, or modern blueprints.
NOTE · en
6 MUST HAVE PRODUCTS FOR PET OWNERS
If you’re welcoming a pet into your home for the first time, you’re likely scouring the internet for advice on how to ensure your new companion is well cared for and content. However, with the pet market overflowing with products—ranging from the necessary to the downright bizarre—determining what’s truly essential can feel overwhelming and confusing.
NOTE · en
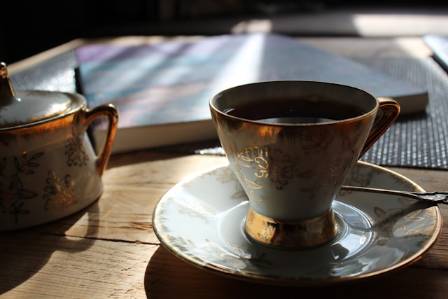
Grandma’s China Can Elevate Your Table Any Night of the Week!
Setting a modern table with vintage china may seem like a challenge at first.
NOTE · en
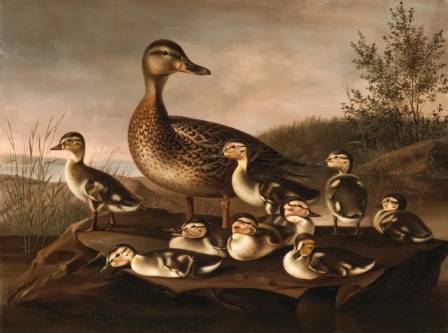
Easy Step-by-step Guide to duck drawing
Ducks are delightful creatures, known for their cheerful quacking and their charming waddle. Drawing ducks can be surprisingly easy and a lot of fun! Whether you want a cute cartoon duck or a more detailed illustration, this step-by-step guide will show you how. Let’s dive in!
NOTE · en
The Most Monumental Antelopes on Earth
While the word "antelope" might conjure images of swift, slender gazelles darting across the plains, the animal family is far more diverse. Beyond the sprinters lie titans—formidable, majestic creatures that rival large cattle in sheer size and power. These are not merely large deer; they are the heavyweights of the antelope world, engineered by evolution to dominate the grasslands, savannas, and forests they call home. This is a journey to meet the most colossal members of this incredible group.